
EMLID / GNSS + FIELD WORKFLOWS
Emlid GNSS and RTK Solutions in Singapore
Emlid designs GNSS receivers and surveying software for professionals who need corrected positioning, practical field workflows and usable geospatial information. Easepect helps organisations select, configure and deploy the appropriate system for surveying, construction, utility mapping, GIS and drone operations.
Observed data, configuration and quality evidence remain attached through handover.
01 / PRACTICAL OVERVIEW
Survey with confidence. Capture with precision. Deliver better geospatial data.
Survey with confidence. Capture with precision. Deliver better geospatial data. The working system begins with the measurements and evidence a project needs—not with a receiver model. A lightweight rover may suit visible-asset collection, while a base-capable all-band receiver may be more appropriate for independent control, setting out or drone work.
Easepect connects receiver selection with correction access, coordinate verification, field collection, processing and handover. We can arrange a demonstration, define a compatible hardware and software stack, and train field and office roles. Product supply does not replace professional survey judgement, project acceptance procedures or regulated responsibilities.
02 / CHOOSE YOUR RTK RECEIVER
Four current receivers. Four distinct field roles.
Start with base/rover responsibility, correction access and required observation method. Camera and scanning functions are not interchangeable.
Reach RS4 Pro
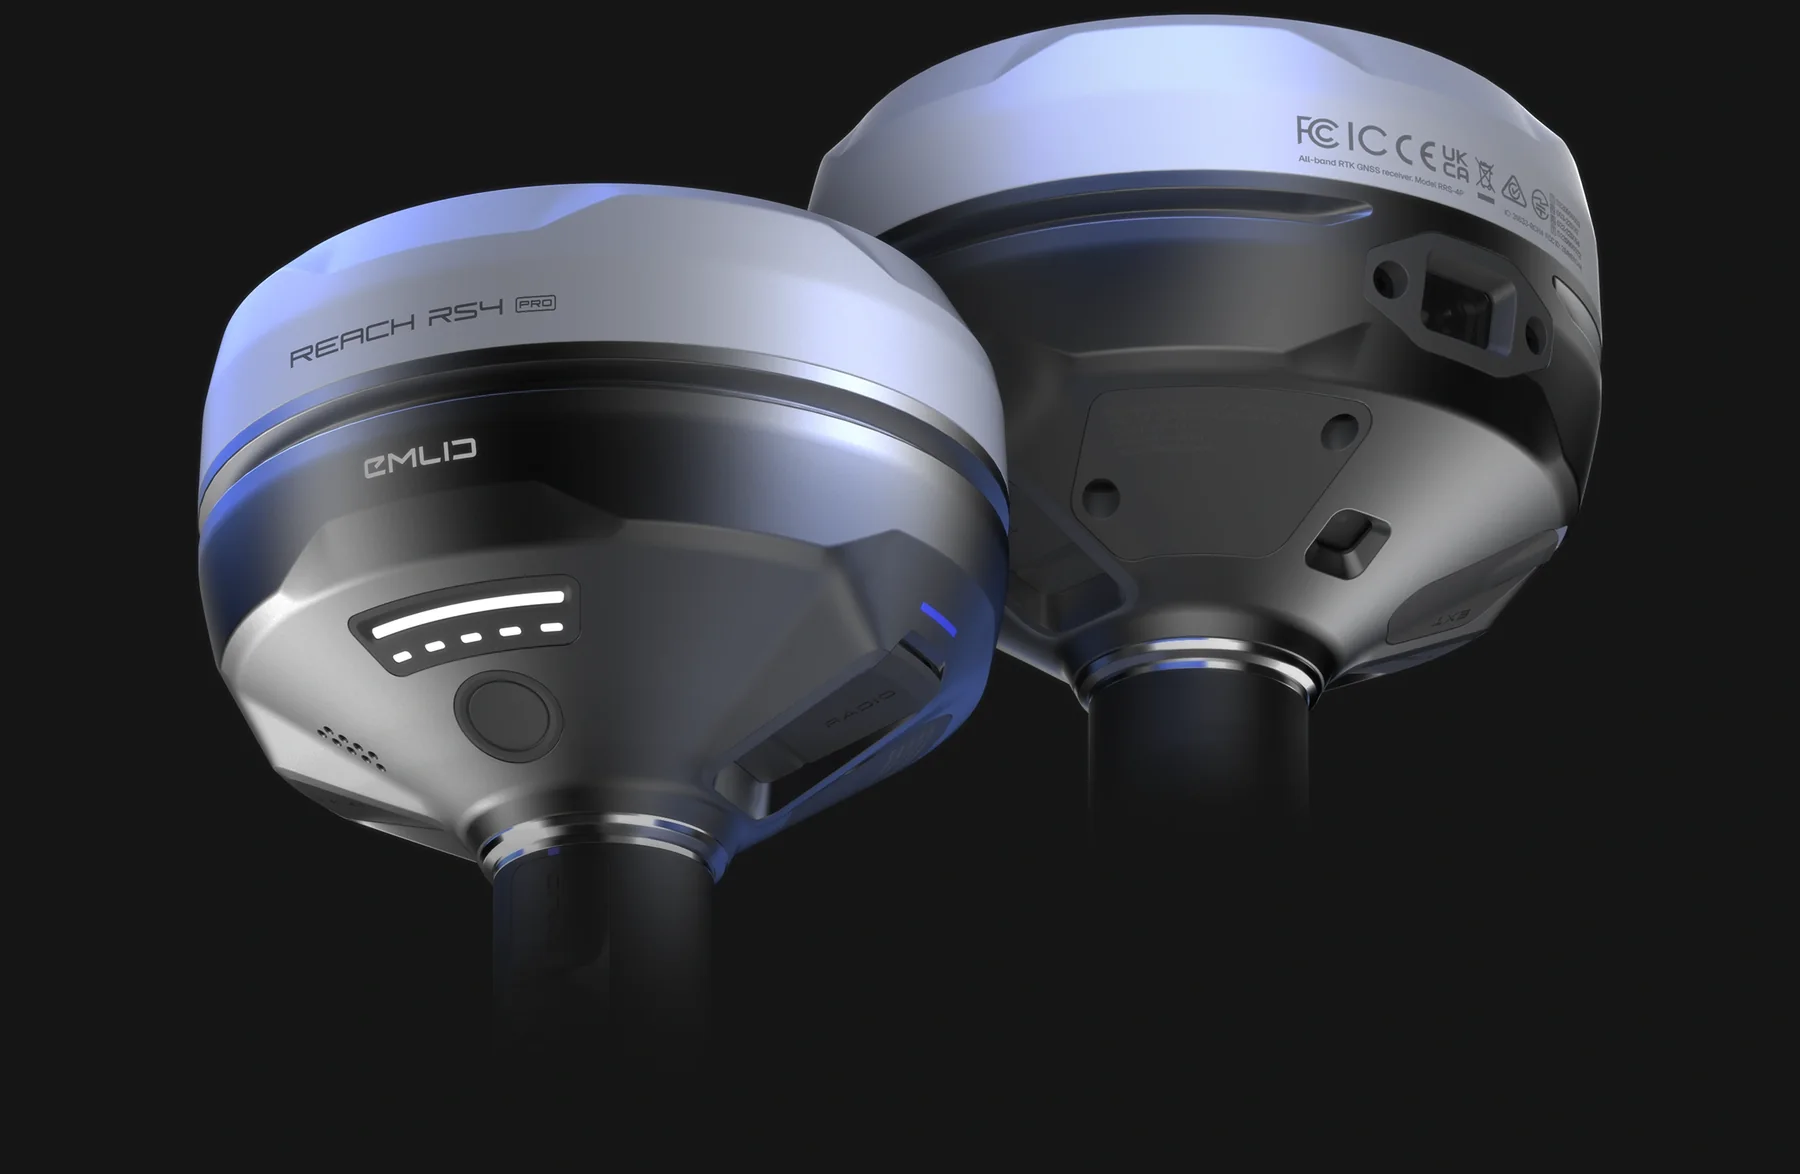
Reach RS4 Pro is an all-band RTK GNSS base and rover with IMU tilt compensation and two integrated Full HD cameras. It suits surveyors and engineering teams that need conventional GNSS observation plus supported AR stakeout and measurement of suitable individual points from images.
Explore Reach RS4 Pro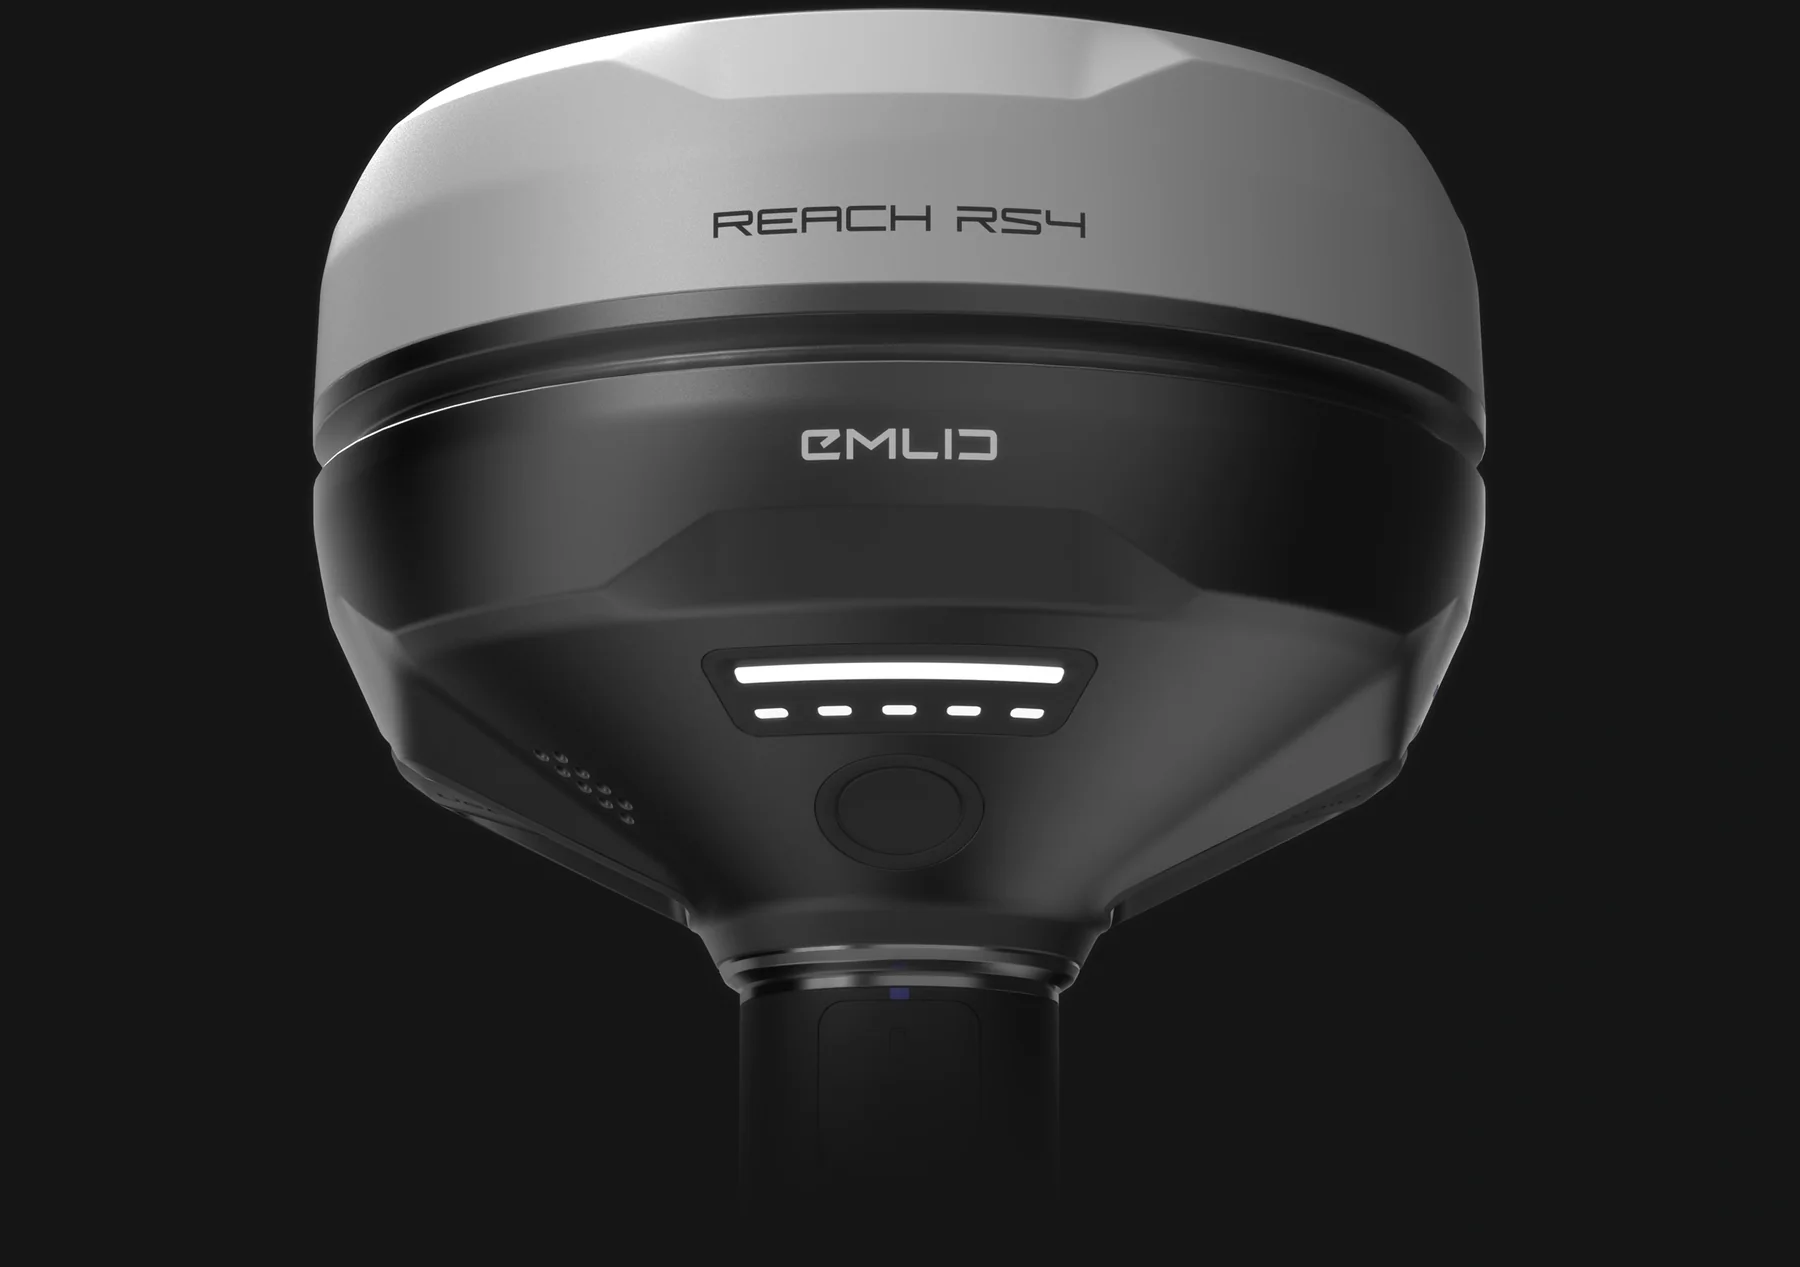
Reach RS4
Reach RS4 is a 672-channel all-band RTK GNSS receiver for base and rover operation, with IMU tilt compensation, RINEX logging and Emlid Flow integration. It suits teams that need professional positioning without the RS4 Pro’s integrated dual-camera visual functions.
Explore Reach RS4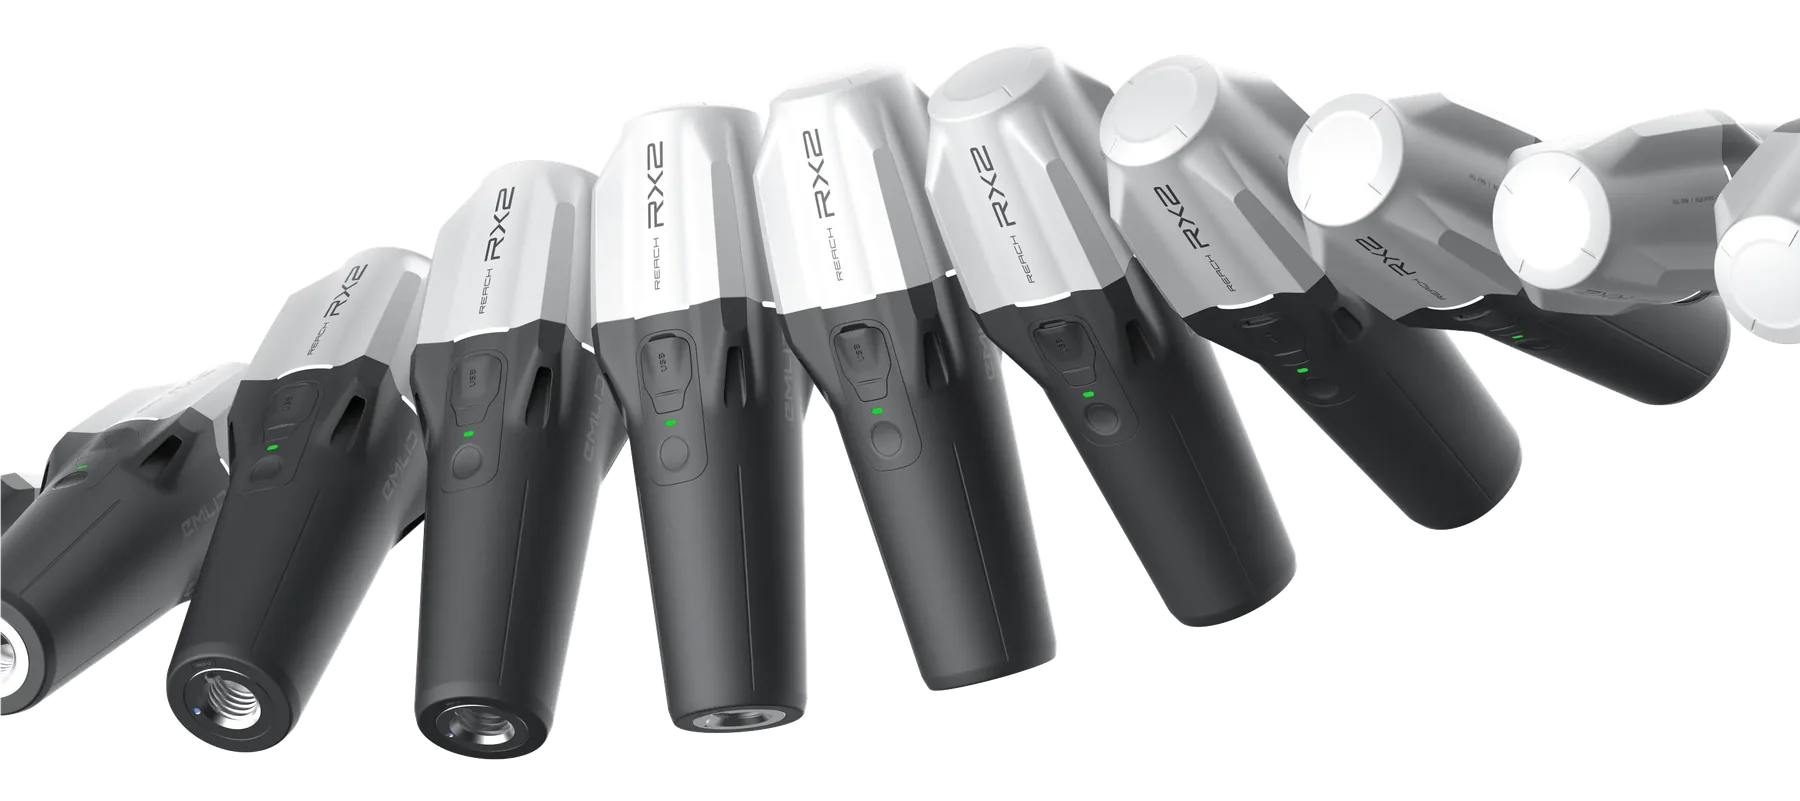
Reach RX2
Reach RX2 is a 280 g all-band RTK rover with IMU tilt compensation and Bluetooth connectivity. It suits mobile survey, GIS and utility asset collection, and can provide corrected positions to supported PIX4Dcatch workflows on compatible iOS devices.
Explore Reach RX2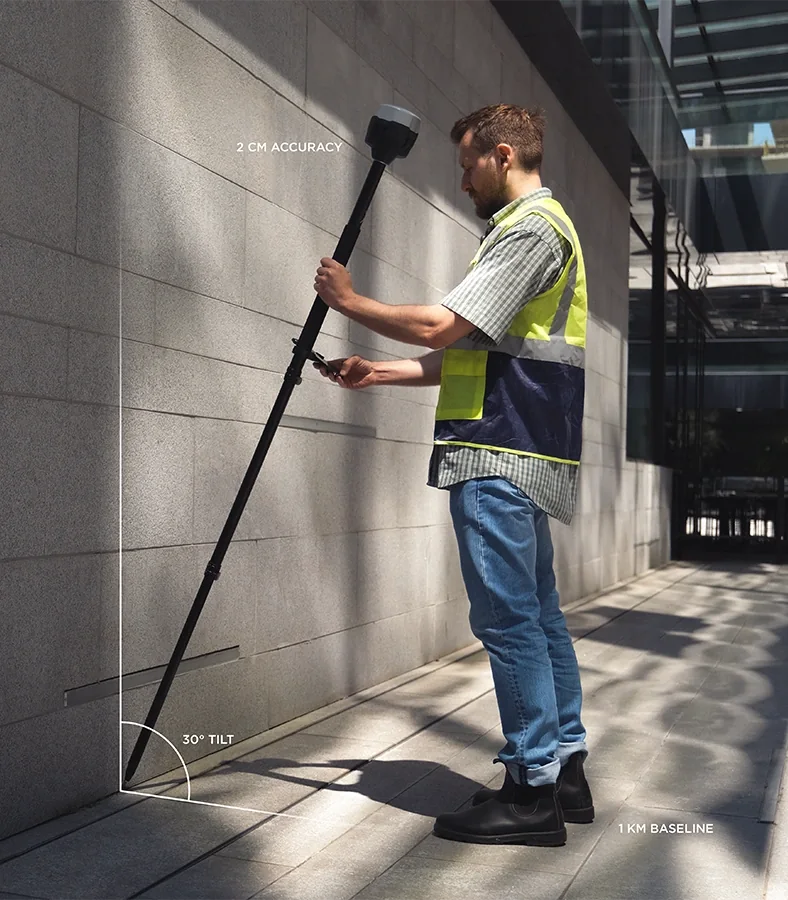
Reach RS3
Reach RS3 is a multi-band RTK GNSS receiver for base and rover operation, with IMU tilt compensation up to 60°, Emlid Flow surveying and RINEX logging. It suits general survey, construction and mapping teams whose requirements align with its 184-channel L1/L2/L5 platform.
Explore Reach RS3Manufacturer reference images illustrate the documented software workflows.
03 / MORE THAN GNSS HARDWARE
One field system, with distinct responsibilities.
Emlid Flow + Flow 360
Configure Reach receivers, manage corrections, collect and stake out features, and coordinate projects between field and office. Free and Pro capabilities are identified separately.
Emlid Studio
Post-process supported static and kinematic GNSS observations, convert logs to RINEX and geotag drone imagery for downstream photogrammetry.
Emlid Caster
Relay RTCM corrections from your own compatible base to connected rovers over the internet. A caster is not a correction-generating network by itself.
PIX4D + Emlid
Combine Reach RX2 positioning with supported PIX4Dcatch iOS capture, then process imagery separately into georeferenced spatial outputs.
04 / BUILT FOR SINGAPORE WORKFLOWS
Positioning that survives the handover.
01 / Establish the reference
Agree SVY21 or the required horizontal system, height reference, control, correction source and independent check points before collection.
02 / Configure the route
Use an appropriate SiReNT subscription, another compatible NTRIP service or a correctly established local base. Internet access alone is not a correction subscription.
03 / Observe and verify
Collect points, lines and polygons with suitable occupation and tilt practices. Check known control and record correction and solution status.
04 / Integrate the evidence
Export survey features for CAD/GIS, connect ground control to photogrammetry where applicable, and preserve QA notes and exceptions.
05 / SELECTION GUIDE
Choose by role, environment and output.
| Project requirement | Starting point | Decision to confirm |
|---|---|---|
| Visual stakeout and selected image-based points | Reach RS4 Pro | Camera workflow, site visibility and supported Flow functions |
| Professional all-band base and rover | Reach RS4 | Correction link, accessories and radio/NTRIP arrangement |
| Lightweight GIS and compatible mobile scanning | Reach RX2 | External correction source and supported iOS/PIX4Dcatch route |
| General multi-band base and rover survey | Reach RS3 | Whether its capabilities suit the operating environment |
| Onboard UAV RTK/PPK and camera events | Reach M2 | Aircraft, power, antenna, triggering and integration engineering |
06 / WHY EASEPECT
Connect the equipment to the actual deliverable.
Easepect combines positioning equipment, photogrammetry software, GIS knowledge, practical project workflows and professional training. We help customers connect GNSS field measurement, coordinate verification, point and line collection, photogrammetry where applicable, processing and QA/QC into CAD/GIS-ready information.
Accuracy depends on correction quality, coordinate systems, calibration, observation conditions and field QA/QC. We therefore scope demonstrations and training around realistic operating conditions and required outputs rather than promising a universal result from a specification sheet.
07 / FREQUENTLY ASKED QUESTIONS
Before choosing Emlid overview.
Start with the role and deliverable. RS4 Pro adds dual-camera visual functions; RS4 is an all-band base/rover without those cameras; RX2 is a lightweight rover only; RS3 is a multi-band base/rover. Easepect can assess your site, corrections and outputs without requiring you to nominate a model first.
Compatible Reach rovers can be configured for NTRIP corrections, but SiReNT requires an appropriate valid subscription, credentials and correct mountpoint/configuration. Verify the exact workflow with SLA and test on known control before production use.
No. A rover can use a suitable subscribed correction network where coverage and project requirements allow. A local base is useful for independent control or sites without a suitable network, but it must be established and configured correctly.
GNSS records positions and observations. A point cloud requires another capture method, such as photogrammetry or laser scanning, plus processing. RS4 Pro visual capture measures suitable individual points; it is not full-scene photogrammetric reconstruction.
No. Solution status is only one part of the evidence. Coordinate and height references, base position, offsets, observation method, site conditions and independent checks all matter, as do professional and contractual requirements.
LOCAL IMPLEMENTATION / SINGAPORE
Not sure which Emlid receiver suits your project?
Tell us what you are surveying, your operating environment and required deliverables. Model selection is optional; Easepect can help identify a suitable hardware and software workflow.